Toothed parallel gripper VGFR36-96
Two‑finger pneumatic gripper for automation and industrial robots — built for reliability and precision.
- Workpiece weight
- 2.5 kg
- Stroke per jaw
- 8 mm
- Opening force
- 84×P N
- Closing force
- 78×P N
- Gripper weight
- 0.5 kg
-
Additional specifications VGFR36-96
SpecificationsBase versionVGFR36-96Normally openVGFR36-96-NONormally closedVGFR36-96-NCNumber of fingers 2 pcs 2 pcs 2 pcs Principle of Operation parallel, rack and pinion Maximum finger opening 110 mm 110 mm 110 mm Theoretical maximum gripping force: opening/closing 84P/78P N 84P/- N -/78P N Maximum allowable single-finger gripping weight 0.7 kg 0.7 kg 0.7 kg Repeated gripping accuracy ± 0.02 mm ± 0.02 mm ± 0.02 mm Opening/closing time 0.035/0.035 sec 0.03/0.05 sec 0.05/0.03 sec Air consumption per cycle 0.124 l 0.188 l 0.188 l Operating temperature 0~60 °C P: Operating air pressure 3~8 bar Protection rating IP40 Gripper weight 0.5 kg 0.6 kg 0.6 kg Base versionVGFR36-96 Base version- Number of fingers
- 2 pcs
- Principle of Operation
- parallel, rack and pinion
- Maximum finger opening
- 110 mm
- Theoretical maximum gripping force: opening/closing
- 84P/78P N
- Maximum allowable single-finger gripping weight
- 0.7 kg
- Repeated gripping accuracy
- ± 0.02 mm
- Opening/closing time
- 0.035/0.035 sec
- Air consumption per cycle
- 0.124 l
- Operating temperature
- 0~60 °C
- P: Operating air pressure
- 3~8 bar
- Protection rating
- IP40
- Gripper weight
- 0.5 kg
Normally openVGFR36-96-NO- Number of fingers
- 2 pcs
- Principle of Operation
- parallel, rack and pinion
- Maximum finger opening
- 110 mm
- Theoretical maximum gripping force: opening/closing
- 84P/- N
- Maximum allowable single-finger gripping weight
- 0.7 kg
- Repeated gripping accuracy
- ± 0.02 mm
- Opening/closing time
- 0.03/0.05 sec
- Air consumption per cycle
- 0.188 l
- Operating temperature
- 0~60 °C
- P: Operating air pressure
- 3~8 bar
- Protection rating
- IP40
- Gripper weight
- 0.6 kg
Normally closedVGFR36-96-NC- Number of fingers
- 2 pcs
- Principle of Operation
- parallel, rack and pinion
- Maximum finger opening
- 110 mm
- Theoretical maximum gripping force: opening/closing
- -/78P N
- Maximum allowable single-finger gripping weight
- 0.7 kg
- Repeated gripping accuracy
- ± 0.02 mm
- Opening/closing time
- 0.05/0.03 sec
- Air consumption per cycle
- 0.188 l
- Operating temperature
- 0~60 °C
- P: Operating air pressure
- 3~8 bar
- Protection rating
- IP40
- Gripper weight
- 0.6 kg
CONFIGURATION OPTIONS- B: Bottom ventilation
- P: IP64 protection rating with dust cover
- NO/NC: Self-locking when open / self-locking when closed
- H: High-temperature resistance
-
Description VGFR36-96
Toothed parallel pneumatic gripper VGFR36-96
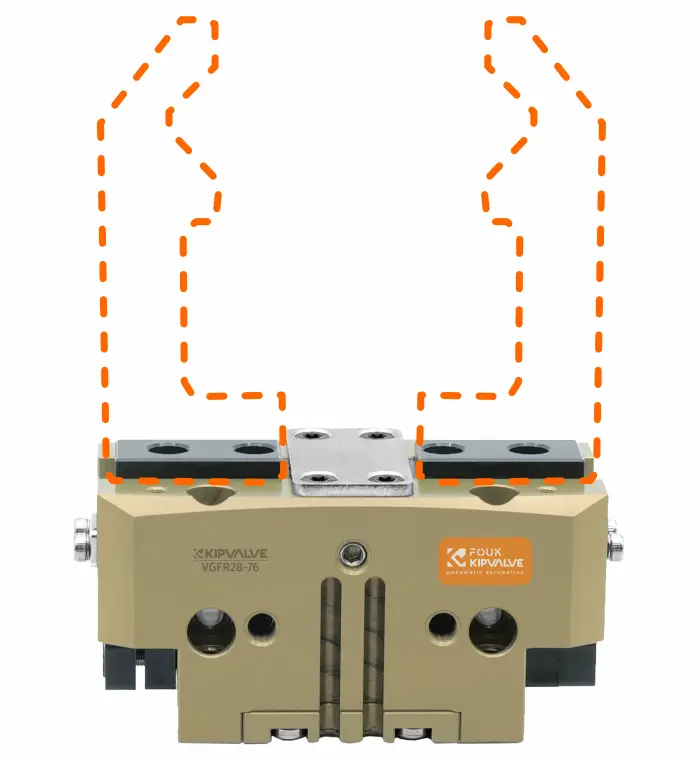
The VGFR36-96 two‑finger parallel pneumatic gripper is a high‑precision workholding device designed for secure holding and accurate positioning of workpieces within industrial robot systems and machine automation cells. This pneumatic gripper is in high demand in metalworking, assembly lines, and foundry operations, where stable performance under intensive cycle conditions and high dynamic loads is essential.
Design features and benefits
A key element of the design is the toothed guide, which, compared to traditional T‑slot configurations, provides increased load capacity, resistance to lateral and moment loads, as well as a significantly extended service life without loss of precision. The housing is manufactured from high‑strength anodised aluminium, ensuring rigidity with minimal inertia mass — a critical factor for high‑speed operations. The parallel jaw motion ensures consistent clamping force and high positioning repeatability.
Gripper system components
To create a comprehensive and reliable solution, we recommend complementing the base module with the following components:
Compensation units – to compensate for misalignment and protect the gripper from lateral overloads during robot interaction.
Quick‑change fingers and jaws – for rapid adaptation of the gripper kinematics to the specific geometry of your workpiece.
Rotary module – to change the spatial orientation of the part during handling without interrupting the production cycle.
-
Dimensions & Drawings VGFR36-96
Чертеж для данного товара отсутствует.