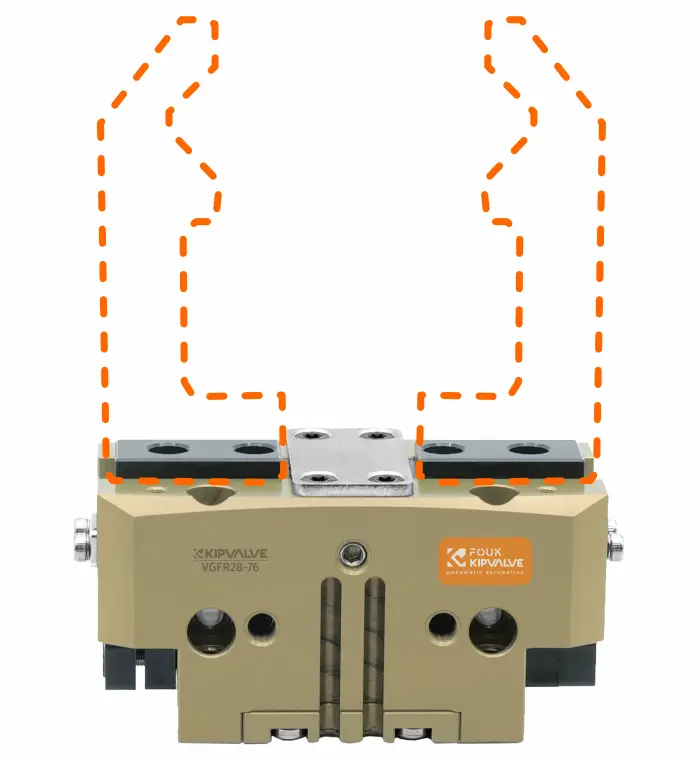
Toothed parallel pneumatic gripper VGFR99-234
Parallel pneumatic gripper for heavy parts.
- Workpiece weight
- 20 kg
- Gripper weight
- 6.1 kg
- Stroke per jaw
- 25 mm
- Opening force
- 560×P N
- Closing force
- 524×P N
-
Additional specifications VGFR99-234
SpecificationsBase versionVGFR99-234Normally openVGFR99-234-NONormally closedVGFR99-234-NCNumber of fingers 2 pcs 2 pcs 2 pcs Principle of Operation parallel, rack and pinion Maximum allowable single-finger gripping weight 7 kg 7 kg 7 kg Maximum finger opening 220 mm 220 mm 220 mm Theoretical maximum gripping force: opening/closing 573P/521P N 573P/- N -/521P N Air consumption per cycle 2.4 l 4.1 l 3.9 l Opening/closing time 0.28/0.28 sec 0.24/0.55 sec 0.55/0.24 sec Repeated gripping accuracy ± 0.03 mm ± 0.03 mm ± 0.03 mm P: Operating air pressure 3~8 bar Operating temperature 0~60 °C Protection rating IP40 Gripper weight 6.1 kg 7.7 kg 7.4 kg Base versionVGFR99-234 Base version- Number of fingers
- 2 pcs
- Principle of Operation
- parallel, rack and pinion
- Maximum allowable single-finger gripping weight
- 7 kg
- Maximum finger opening
- 220 mm
- Theoretical maximum gripping force: opening/closing
- 573P/521P N
- Air consumption per cycle
- 2.4 l
- Opening/closing time
- 0.28/0.28 sec
- Repeated gripping accuracy
- ± 0.03 mm
- P: Operating air pressure
- 3~8 bar
- Operating temperature
- 0~60 °C
- Protection rating
- IP40
- Gripper weight
- 6.1 kg
Normally openVGFR99-234-NO- Number of fingers
- 2 pcs
- Principle of Operation
- parallel, rack and pinion
- Maximum allowable single-finger gripping weight
- 7 kg
- Maximum finger opening
- 220 mm
- Theoretical maximum gripping force: opening/closing
- 573P/- N
- Air consumption per cycle
- 4.1 l
- Opening/closing time
- 0.24/0.55 sec
- Repeated gripping accuracy
- ± 0.03 mm
- P: Operating air pressure
- 3~8 bar
- Operating temperature
- 0~60 °C
- Protection rating
- IP40
- Gripper weight
- 7.7 kg
Normally closedVGFR99-234-NC- Number of fingers
- 2 pcs
- Principle of Operation
- parallel, rack and pinion
- Maximum allowable single-finger gripping weight
- 7 kg
- Maximum finger opening
- 220 mm
- Theoretical maximum gripping force: opening/closing
- -/521P N
- Air consumption per cycle
- 3.9 l
- Opening/closing time
- 0.55/0.24 sec
- Repeated gripping accuracy
- ± 0.03 mm
- P: Operating air pressure
- 3~8 bar
- Operating temperature
- 0~60 °C
- Protection rating
- IP40
- Gripper weight
- 7.4 kg
CONFIGURATION OPTIONS- B: Bottom ventilation
- P: IP64 protection rating with dust cover
- NO/NC: Self-locking when open / self-locking when closed
- H: High-temperature resistance
-
Description VGFR99-234
Two-finger parallel pneumatic gripper for heavy workpieces
The VGFR99-234 pneumatic two-finger parallel gripper is designed for secure workpiece holding and precise positioning of large components weighing up to 33 kg within industrial robot systems, CNC machining centres, and assembly lines. This model is widely used in heavy machinery manufacturing, metalworking, foundry operations, and logistics where stable performance under high cycle rates and dynamic loads is essential.
Design features and benefits
The toothed guide, developed on the principle of a chuck mechanism, provides increased load capacity and resistance to lateral and moment loads, significantly outperforming traditional T-slot designs in terms of service life. The wedge drive mechanism synchronises jaw motion, ensuring high repeatability (±0.03 mm) and consistent clamping force regardless of the contact point. The anodised aluminium body makes the gripper rigid and corrosion-resistant at a moderate weight (5.6 kg), which is critical for high-speed operations. The side pneumatic port simplifies installation in confined spaces.
Modifications and Options
The base VGFR99-234 model can be enhanced with options to suit specific working conditions: IP64 dust protection cover (P), self-locking with normally open (NO) or normally closed (NC) springs, high-temperature version up to 240°C (H), and a short-stroke version (S) with 14 mm travel for more compact workpieces. Inductive and magnetic proximity sensors are available for finger position monitoring.
System Integration and Compatibility
For a complete solution, the VGFR99-234 base gripper can be supplemented with replaceable fingers, adapter flanges for robot or equipment mounting, and ZM-40X-A quick-change fingers for rapid changeover between different workpiece types. Compatibility with compensation modules and rotary units further expands functionality and protects the gripper from overloads.
-
Dimensions & Drawings VGFR99-234
Чертеж для данного товара отсутствует.